
 openelab.de
 openelab.com






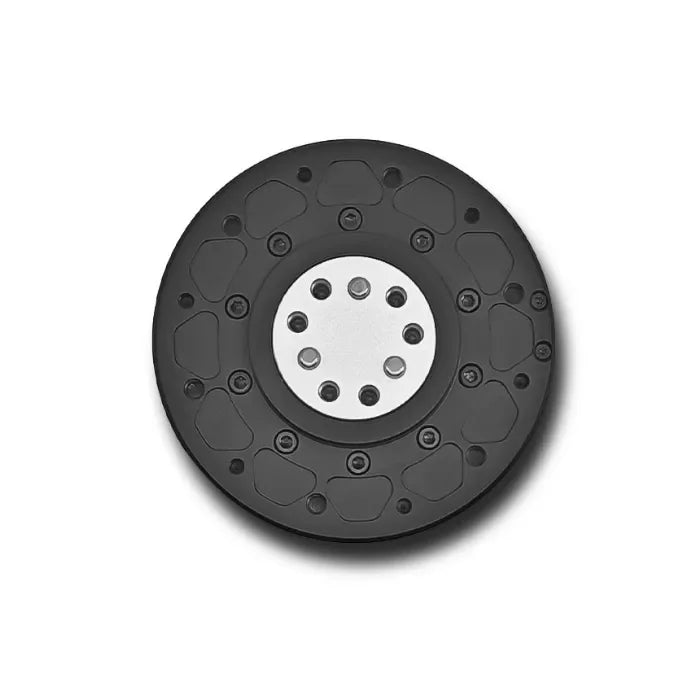



































CubeMars AK45-36 KV80 BLDC Robotic Actuator
Need a larger quantity?
Need bulk pricing?
Get a formal quotation with lead time and volume pricing.
For universities, companies, distributors, and project orders.
CubeMars AK45-36 KV80 BLDC Robotic Actuator
CubeMars AK45-36 KV80 is a BLDC robotic actuator for compact robot joints and articulated research mechanisms. Its 36:1 planetary reduction provides 8Nm rated output torque and 24Nm peak output torque, with 24V as the published supply reference.
The driven actuator combines the motor, planetary gearbox and motor-control electronics. Match the installed board, winding and software generation before commissioning: a similar motor name or reduction ratio does not make driver boards, firmware and connection leads interchangeable. RUBIK LINK is a separate accessory.
CubeMars Motor Application Guide
CubeMars motors and actuators cover humanoid joints, quadruped platforms, exoskeletons, custom frameless drives, gimbals and underwater propulsion. Application categories identify starting points; final selection depends on the exact model, control configuration and load case.
| Motor Type | Actuator Model | Technical Description |
|---|---|---|
| Shoulder Joint Motor | AK60-39 V3.0 | A starting point for humanoid shoulder mechanisms and multi-axis arm motion. Evaluate arm inertia, payload, moment arm, output-bearing loads and duty cycle for each axis; the application label is not a verified complete-arm load rating. |
| Elbow Joint Motor | AK70-9 V3.0 | A candidate for robotic elbow flexion and extension. Match the complete arm load cycle, required output speed, mechanical envelope and feedback configuration before integration. |
| Wrist Joint Motor | AK45-10 | An option for compact wrist mechanisms. Compare end-effector mass, cable routing, output-bearing loads and the exact driver and feedback configuration for the selected version. |
| Neck Joint Motor | AK40-10 | A candidate for robotic head positioning. Check head inertia, joint geometry, movement range and feedback requirements; validate the assembled mechanism rather than assuming a motor alone establishes positioning performance. |
| Hip Joint Motor | AKH70-48 V1.0 | A starting point for humanoid hip mechanisms. Evaluate body mass, gait-dependent torque and speed, transmission geometry, thermal duty cycle and mechanical margins for the complete leg. |
| Knee Joint Motor | AK80-64 | An option for knee flexion and extension mechanisms. Check the torque profile throughout the motion cycle, required speed, impact loading and thermal demand before selecting the joint assembly. |
| Ankle Joint Motor | AKH70-16 V1.0 | A candidate for robotic ankle mechanisms. Evaluate foot geometry, ground-contact loads, motion range and system-level balance-control requirements separately from the actuator specification. |
| Robot Joint Module |
AK10-9 V3.0 AK10-9 V2.0 KV100 AK10-9 V2.0 KV60 AK80-9 V3.0 AK80-8 AK80-6 AK80-64 AK70-10 AK70-9 V3.0 AK60-6 V3.0 AK60-6 V1.1 KV140 AK45-36 AK45-10 AK40-10 AK60-39 V3.0 KV80 AKH70-16 KV41 AKH70-48 KV41 AK40-10 V3.0 KV170 AK45-10 V3.0 KV75 AK45-36 V3.0 KV80 AK70-9 KV60 |
AK- and AKH-series modules for general robotic joints. Compare exact generations, gearbox ratios, supply voltage, bearing loads, feedback hardware, driver options and host interfaces; these configurations are not interchangeable solely because their model names are similar. |
| Robot Dog Motor |
AK10-9 V3.0 AK10-9 V2.0 KV100 AK10-9 V2.0 KV60 AK80-9 V3.0 AK80-8 AK80-6 AK80-64 AK70-10 AK60-6 V3.0 AK60-6 V1.1 AK45-36 AK45-10 AK40-10 |
Candidates for quadruped robot joints. Calculate gait-dependent torque and speed, impact loads, body mass and thermal demand for each axis. Vehicle speed, jumping ability and terrain performance require complete-system validation. |
| Rehabilitation Robot Motor |
AK10-9 V2.0 KV100 AK10-9 V2.0 KV60 RI80 V2.0 RI70 RI60 RI50 |
Geared actuator modules and frameless motors for rehabilitation-device and assistive-mechanism development. Confirm transmission design, sensing and control limits. Medical-device suitability, certification and system safety are not established by inclusion in this guide. |
| Exoskeleton Motor |
AKE50-8 KV110 AKE40-6 KV90 AKE90-8 KV35 AKE80-8 KV30 AKE60-8 KV80 |
AKE quasi-direct-drive assemblies for exoskeleton research and lightweight robotic joints, including AKE50-8 KV110 and AKE40-6 KV90. Compare the model-specific mass, reduction ratio and torque-speed requirements, and confirm the exact driver and encoder configuration. |
| Motor Setup and Feedback Accessories |
R-LINK V3.0 R-LINK V2.0 S-LINK V1.0 AS5048A encoder module |
Setup and feedback accessories, not motors or automatically included package items. Select R-LINK, S-LINK and encoder hardware against the exact motor generation, driver, firmware and connector documentation. These links do not imply compatibility with every CubeMars product or underwater thruster. |
| Subsea ROV and AUV Thruster |
DW15 DW10 DW25 DW20 |
DW10, DW15, DW20 and DW25 for subsea ROV/AUV propulsion. Their published operating-depth range is 0-350m. Match supply, thrust, CW/CCW configuration and external ESC, and verify the complete installed system for its pressure exposure. |
| Gimbal and PTZ Motor |
G35 KV100 GL100 KV10 G100 KV10 G80 KV30/KV60 G60 KV25/KV55 G40 KV70/KV210 GL80 KV60 GL80 KV30 GL40 KV210 GL35 KV100 GL30 KV290 GL60 KV25 GL60 II KV28 GL40 II KV82.5 GL40 KV70 |
G- and GL-series motors for gimbals, pan-tilt platforms and stabilized payload development. Encoder options, driver integration and interfaces vary by model. Keep GL II configurations distinct and verify payload inertia, balancing and controller requirements. |
| Shallow-Water Thruster |
SW17 SW12 SW7 |
SW7, SW12 and SW17 for surface and shallow-water propulsion, handheld thrusters and electric-surfboard development. Their published operating-depth range is 0-30m. Select the exact voltage, CW/CCW version and external ESC separately. |
| Marine Robotics Thruster Kit | W30 | W30 complete thruster kit for marine-robotics and ROV/AUV/USV prototyping. The kit includes its matching ESC and CW/CCW propeller pair. The thruster depth rating does not automatically cover the ESC, connections or the complete vehicle. |
| Frameless Outrunner Torque Motor |
RO100 KV55 Lite RO100 KV55 Hall RO60 KV115 Hall RO80 KV105 Lite RO80 KV105 Hall RO60 KV115 Lite RO40 KV140 Lite RO50 KV108 Lite |
RO-series frameless outrunner motors for custom rotary joints and compact mechanisms. Keep Lite and Hall configurations distinct, and verify the mounting, bearings, motor feedback and external controller for the exact product. |
| Frameless Inrunner Torque Motor |
RI115-PH KV40 RI85-PH KV85 RI75-PH KV70 RI100 KV105 RI80 V2.0 KV75 RI70 KV95 RI60 KV120 RI50 KV100 |
RI-series frameless inrunner motors, including the PH potted configurations, for embedded and custom joint designs. Plan the housing, bearings, thermal path, rotor-stator alignment, feedback and external drive as part of the complete assembly. |
| AGV and Mobile Robot Motor |
AKA10-9 KV60 AKA60-6 KV80 |
AKA-series actuators for AGV, mobile-robot and inspection-platform drive development. Check radial loading, wheel or transmission geometry, operating torque and speed, supply voltage and the selected control configuration. |
| Direct-Drive Torque Motor | R100 KV90 | A BLDC torque-motor option for custom rotary-drive assemblies. Confirm the motor feedback arrangement, supply, controller commutation, thermal path and mechanical interface; do not infer compatibility with an actuator driver from the brand name alone. |
Features
- Model-specific output sizing - 8Nm rated output and 24Nm peak output distinguish normal design loading from short transient demand. Evaluate the real torque-speed cycle, cooling and driver limits.
- Defined planetary reduction - 36:1 is the mechanical reduction ratio for AK45-36 KV80. Compare it with required joint speed and reflected load inertia rather than selecting by motor diameter alone.
- Supply-dependent performance - 24V is the published supply reference. Size the complete power path for the actual supply and operating current.
- Driven actuator configuration - The motor selection includes the integrated driver; the separately listed RUBIK LINK interface is used for setup and is not another motor.
- Feedback matched to the hardware - Single magnetic encoder reference for the With Driver assembly; resolution is not axis accuracy; verify the firmware and feedback configuration before enabling motion.
- Backdrive behavior - 0.8Nm is the listed resistance to externally driven rotation. It is not output torque, a brake holding rating or an automatic safety function.
- Transmission clearance - 12 arcmin is the gearbox backlash reference. It is not complete-axis positioning accuracy and should be included in the mechanical error budget.
- Board-specific commissioning - AK40-2410-1A-A1 is the manufacturer's driver reference for this model. Confirm the board label and matched instructions before wiring or changing firmware.
- Thermal and duty-cycle planning - Rated and peak figures require an appropriate mounting and cooling arrangement. Continuous stall, impact loading and repeated acceleration should be verified with the actual mechanism.
- Engineering resources by configuration - Matched drawings, available software and model-specific support files are grouped below. Use the exact winding, driver revision and firmware family; a newer-looking filename is not evidence of compatibility.
Construction and Connection Details


Specifications
Electrical interfaces and feedback references below describe the driven actuator. W/O Driver, where offered, is a separate integration configuration.
| Parameter | Value |
|---|---|
| Brand / model | CubeMars AK45-36 KV80 |
| Motor construction | BLDC motor and planetary gearbox; integrated driver on the driven motor option |
| Rated supply reference | 24V |
| Rated output torque | 8Nm |
| Peak output torque | 24Nm |
| Rated output speed | 40rpm |
| Reduction ratio | 36:1 |
| No-load output speed | 52rpm |
| Rated current | 2A DC |
| Peak current | 6.5A DC |
| Reference assembly mass | 340g |
| Reference assembly dimensions | diameter 55 x 54mm |
| Gearbox backlash | 12 arcmin |
| Backdrive torque reference | 0.8Nm |
| Drive / feedback scope | Single magnetic encoder reference for the With Driver assembly; resolution is not axis accuracy |
| Driver reference | AK40-2410-1A-A1; match the supplied driver revision before commissioning |
| Driver interface reference | XT30(2P)+GH125(4P) |
The motor selection and the separate RUBIK LINK option are different purchases. The debug interface is not a motor-and-driver bundle and is not automatically included with the actuator.
Peak output is not a continuous stall rating. Validate cooling, duty cycle, controller limits and output-bearing loads in the complete mechanism.
CubeMars AK Actuator Comparison
These are model reference ratings, not complete-robot payload, positioning-accuracy or unlimited-stall guarantees. Feedback and driver information applies to the driven configuration unless stated otherwise.
| Model | Supply | Reduction | Rated Torque | Peak Torque | Drive / Feedback |
|---|---|---|---|---|---|
| AK40-10 KV170 | 24V | 10:1 | 1.3Nm | 4.1Nm | Single encoder; driven assembly |
| AK40-10 V3.0 KV170 | 24V | 10:1 | 1.3Nm | 4.1Nm | Dual encoder; driven assembly |
| AK45-10 KV75 | 24V | 10:1 | 2.5Nm | 7Nm | Single encoder; driven assembly |
| AK45-10 V3.0 KV75 | 24V | 10:1 | 2.5Nm | 7Nm | Dual encoder; driven assembly |
| AK45-36 KV80 | 24V | 36:1 | 8Nm | 24Nm | Single encoder; driven assembly |
| AK45-36 V3.0 KV80 | 24V | 36:1 | 8Nm | 24Nm | Dual encoder; driven assembly |
| AK60-6 V3.0 KV80 | 24/48V | 6:1 | 3Nm | 9Nm | Single encoder; driven assembly |
| AK70-10 KV100 | 24/48V | 10:1 | 8.3Nm | 24.8Nm | Single encoder; driven assembly |
| AK60-6 V1.1 KV140 | 24V | 6:1 | 3Nm | 9Nm | Single encoder; driven assembly |
| AK70-9 V3.0 KV60 | 48V | 9:1 | 8.5Nm | 29.2Nm | Dual encoder; driven assembly |
| AK70-9 KV60 | 48V | 9:1 | 8.5Nm | 29.2Nm | Dual encoder; driven assembly |
| AK80-6 KV100 | 48V | 6:1 | 6Nm | 12Nm | Single encoder; driven assembly |
| AK80-8 KV60 | 48V | 8:1 | 10Nm | 25Nm | Dual encoder; driven assembly |
| AK80-64 KV80 | 24/48V | 64:1 | 48Nm | 120Nm | Single encoder; driven assembly |
| AK80-9 V3.0 KV100 | 48V | 9:1 | 9Nm | 22Nm | Single encoder; driven assembly |
| AK10-9 V2.0 KV100 | 24/48V | 9:1 | 18Nm | 48Nm | Dual encoder; driven assembly |
| AK10-9 V2.0 KV60 | 24/48V | 9:1 | 18Nm | 48Nm | Dual encoder; driven assembly |
| AK10-9 V3.0 KV60 | 48V | 9:1 | 18Nm | 53Nm | Dual encoder; driven assembly |
| AK60-39 V3.0 KV80 | 48V | 39:1 | 24Nm | 72Nm | Dual encoder; driven assembly |
CubeMars AK Selection Guide
| Integration Need | Models to Compare | Selection Checks |
|---|---|---|
| Compact24V joint | AK40-10 / AK45-10 / AK45-36, keeping generations separate | Compare output torque, rated speed, reduction ratio and actual driver generation. V3.0 and older models can differ in feedback and envelope even when nominal torque is similar. |
| Low-ratio dynamic axis | 6:1 / 8:1 / 9:1 / 10:1 models | Select the torque-speed operating point and reflected inertia before considering peak torque. Check the actual supplied driver and feedback configuration. |
| Higher-ratio geared output | AK45-36 / AK60-39 / AK80-64 | 36:1 / 39:1 / 64:1 reduction changes output speed, backdrive behavior and the application error budget. Check torque, bearing loads and heat rejection together. |
Product Visuals


Reference Documents
Match the installed board label, motor winding and firmware parameters before changing software or drive settings.
Mechanical Drawings and Model Files
- AK40 -2410-1A-A1 Driver Installation Instructions [ AK40-10 / AK45-10 / AK45-36 ] (PDF)
- AK45-36 Robotic Actuator 2D Drawing (PDF)
- AK45-36 Robotic Actuator 3D Drawing (STEP, ZIP)
Driver and Commissioning Resources
- AK-series-driver-manual-V1-0-18-for-AK-2-0-robotic-actuator (PDF)
- CH340 Driver Download for AK 2.0 Series Motor (ZIP)
- AK Series V1.32 Upper Computer for AK 2.0 Motor (ZIP)
- AK45-36 Firmware and Parameters (RAR)
- Driver AK40-2410-1A-A1 [ AK40-10 / AK45-10 / AK45-36 ] (STEP,ZIP)
Legacy and Board-Specific References
Use these revision-specific references only when the installed motor and board match. They are not interchangeable wiring or firmware instructions.
Application
Articulated robot joints
Size the complete joint against its torque-speed cycle, mechanism geometry and output-bearing loads.
Legged-robot research
Evaluate gait-dependent peak demand, impact loading, structural stiffness and installed thermal limits.
Exoskeleton prototypes
Develop powered joints with independent torque limiting, mechanical stops and application-specific human safety validation.
Assistive-mechanism development
Combine the actuator with the required sensing, guarding and controlled motion envelope; a motor is not a certified medical system.
Laboratory actuator test rigs
Measure current, temperature, backdrive behavior and response with the actual selected driver configuration.
Custom automation axes
Check the transmission, coupling, mounting and controller interfaces before integrating the complete rotary mechanism.
Packing List
Motor Selection
| SKU | Item | Quantity |
|---|---|---|
| CubeMars-AK45-36D | AK45-36 KV80 actuator with its integrated driver | 1 |
| Power cable | 1 | |
| Serial cable | 1 | |
| CAN cable | 1 | |
| Certificate of Conformance | 1 |
RUBIK LINK Selection Only
| SKU | Item | Quantity |
|---|---|---|
| CubeMars-RLINKV2 | RUBIK LINK V2.0 commissioning interface; actuator not included | 1 |
The interface is a separate accessory selection, not an extra motor or a bundled driver in the actuator kit.
FAQ
What is the CubeMars AK45-36 KV80 used for?
AK45-36 KV80 is intended for compact robot joints and articulated research mechanisms. Final payload, accuracy and safety depend on the complete mechanical and control system.
Does the motor selection include a driver?
The driven motor selection includes the actuator driver. Motor (w/o Debug Board) means the external RUBIK LINK debug accessory is not bundled with the motor; it does not mean the actuator driver is absent.
Is RUBIK LINK a motor-and-debug-board bundle?
No. The RUBIK LINK option is a standalone commissioning interface. Select the actuator or the interface as separate items; a debug adapter is not a motor driver or another motor.
What are the torque, supply and reduction references?
24V, 36:1 reduction, 8Nm rated output and 24Nm peak output are the published model references. Peak torque is not a continuous-duty allowance.
Are older AK drivers and V3 drivers interchangeable?
No blanket interchangeability is specified. Check the board label, connectors, motor winding, feedback and software family before changing wiring or firmware. Keep older AK driver resources separate from V3 resources.
Does encoder resolution establish joint accuracy?
No. Encoder resolution, gearbox backlash and assembled-axis accuracy describe different things. Match the feedback hardware and assess the complete error budget rather than treating a bit count as a positioning guarantee.
How should I interpret the rated speed?
The rated output speed is 40rpm. Use the stated supply and load reference. No-load speed is a different operating condition.
Can I use the peak output continuously?
No. Validate motor temperature, heat removal, driver current limits and the actual operating cycle. Repeated acceleration, impact loads and continuous stall require separate system-level evaluation.
What does the packing list cover?
The motor section covers the selected actuator configuration and the verified connection items. The separate RUBIK LINK section is not an extra motor in the actuator kit.
Which engineering and software files should I use?
Use the matched mechanical drawings and the instructions for the actual installed board, winding and feedback hardware. Firmware, software and historical driver references are not interchangeable simply because they are downloadable from the same brand.
1. General Shipping Information
- We provide reliable shipping services with a tracking number for each order.
- Shipping addresses must be entered in English and should not contain special symbols, so that the courier system can recognize your location correctly.
- Please make sure your shipping address is accurate before placing your order. We ship strictly according to the address provided at checkout.
- In-stock orders are usually dispatched within 1 business day after order confirmation.
- Estimated delivery times refer to the period after dispatch and do not include order processing time, weekends, public holidays, customs inspection, or force majeure delays.
- If you need to cancel or modify your order, please contact us before the order is marked as “Shipped”. Once shipped, the order cannot be canceled or changed.
🚀 Need Faster Shipping?
If you require expedited shipping, please contact our customer support team at info@openelab.io for a customized quote based on your destination.
2. Shipping Rates & Options
Shipping rates are calculated based on order value, destination, and available shipping methods. The final available options will be displayed at checkout.
2.1 Germany Domestic Shipping
| Shipping Method | Order Value | Cost | Est. Delivery |
|---|---|---|---|
| Deutsche Post | €0.00 - €50.00 | €4.95 | 2-4 Business Days |
| Deutsche Post | Over €50.00 | Free | 2-4 Business Days |
|
DHL Paket (Faster Delivery) |
€0.00 - €50.00 | €6.95 | 1-3 Business Days |
|
DHL Paket (Faster Delivery) |
€50.00 - €100.00 | €2.00 | 1-3 Business Days |
|
DHL Paket (Faster Delivery) |
Over €100.00 | Free | 1-3 Business Days |
2.2 Selected EU Countries / Regions
Available EU shipping destinations are shown at checkout based on your shipping address. For orders shipped to selected EU countries or regions outside Germany, we use FedEx Regional Economy.
| Shipping Method | Order Value | Cost | Est. Delivery |
|---|---|---|---|
| FedEx Regional Economy | €0.00 - €100.00 | €7.95 | 3-5 Business Days |
| FedEx Regional Economy | Over €100.00 | Free | 3-5 Business Days |
EU orders may be fulfilled from our Munich warehouse or, when applicable, from our Shenzhen warehouse depending on inventory availability. For EU member states, OpenELAB covers applicable import duties and taxes under DDP service where required.
2.3 United States
| Region | Shipping Method | Order Value | Cost | Est. Delivery |
|---|---|---|---|---|
|
Continental U.S. (50 States) |
USPS Ground Advantage | €0.00 - €45.00 | €4.95 | 3-7 Business Days |
| USPS Ground Advantage | Over €45.00 | Free | 3-7 Business Days | |
| USPS Priority Mail | €0.00 - €45.00 | €16.95 | 1-4 Business Days | |
| USPS Priority Mail | Over €45.00 | €14.95 | 1-4 Business Days | |
|
Non-Continental U.S. (AK, HI, PR, etc.) |
USPS Ground Advantage | €0.00 - €60.00 | €6.95 | 5-9 Business Days |
| USPS Ground Advantage | Over €60.00 | Free | 5-9 Business Days |
Non-Continental U.S. regions include Alaska, American Samoa, Guam, Hawaii, the Marshall Islands, the Northern Mariana Islands, Palau, Puerto Rico, the U.S. Virgin Islands, and U.S. Armed Forces addresses.
2.4 International Destinations Outside the EU
For selected international destinations outside the EU, including Switzerland, the United Kingdom, and Norway, shipping rates are as follows:
| Order Amount | Shipping Cost |
|---|---|
| €0.00 - €300.00 | €19.95 |
| Over €300.00 | Free |
For non-EU destinations, import duties, taxes, and customs fees may be charged by the destination country and are the responsibility of the recipient.
3. Warehouses & Fulfillment
Our products may be stored in our Munich, Arlington, and Shenzhen warehouses. The actual shipping warehouse depends on product availability and destination.
3.1 Munich Warehouse
For products stored in our Munich warehouse, we use Deutsche Post or DHL Paket for domestic deliveries within Germany. For selected EU destinations outside Germany, we use FedEx Regional Economy.
3.2 Arlington Warehouse
For products stored in our Arlington warehouse, we use USPS or UPS for deliveries within the United States.
3.3 Shenzhen Warehouse
For pre-order items or products fulfilled directly from our Shenzhen warehouse, we arrange reliable international shipping based on destination and inventory status. For EU member states, OpenELAB covers applicable import duties and taxes under DDP service where required.
4. Inventory, Pre-orders & Split Shipments
- Inventory Status: Please check the product page for real-time stock information. If an item is out of stock in our local warehouses, it may be marked as “Pre-order”.
- Pre-order Fulfillment: Pre-order items may be shipped directly from Shenzhen or restocked to a local warehouse first before final delivery.
- Split Shipments: If your order contains both in-stock and pre-order items, we may ship them separately. No additional shipping fee will be charged for split shipments caused by our fulfillment arrangement.
5. Customs, Taxes & Delivery Issues
5.1 Customs and Taxes
For EU Member States:
Whether shipped from Germany or China, OpenELAB covers applicable import duties and taxes under DDP service where required. Customers in EU member states should not be charged additional import duties or VAT upon delivery.
For destinations outside the European Union, such as Switzerland, Norway, and the United Kingdom, import duties, taxes, and customs fees may be charged by local authorities upon delivery. These fees are the responsibility of the recipient.
5.2 Damaged, Delayed, or Lost Parcels
Please inspect your parcel upon delivery where possible. If you notice visible damage, please report it to the courier and contact us as soon as possible. This does not affect your statutory consumer rights.
If your parcel is delayed, lost, returned to sender, or the tracking information has not updated for an unusual period of time, please contact us at info@openelab.io. We will assist you in checking the shipment status with the courier.
5.3 Incorrect Address or Failed Delivery
If a parcel cannot be delivered due to an incorrect or incomplete address provided by the customer, refusal of delivery, or failure to collect the parcel, additional shipping or return costs may apply.
6. VAT
For orders within the EU, VAT is collected at checkout according to the applicable destination rules. No additional VAT should be collected upon delivery for EU member state orders covered under our DDP shipping arrangement.


